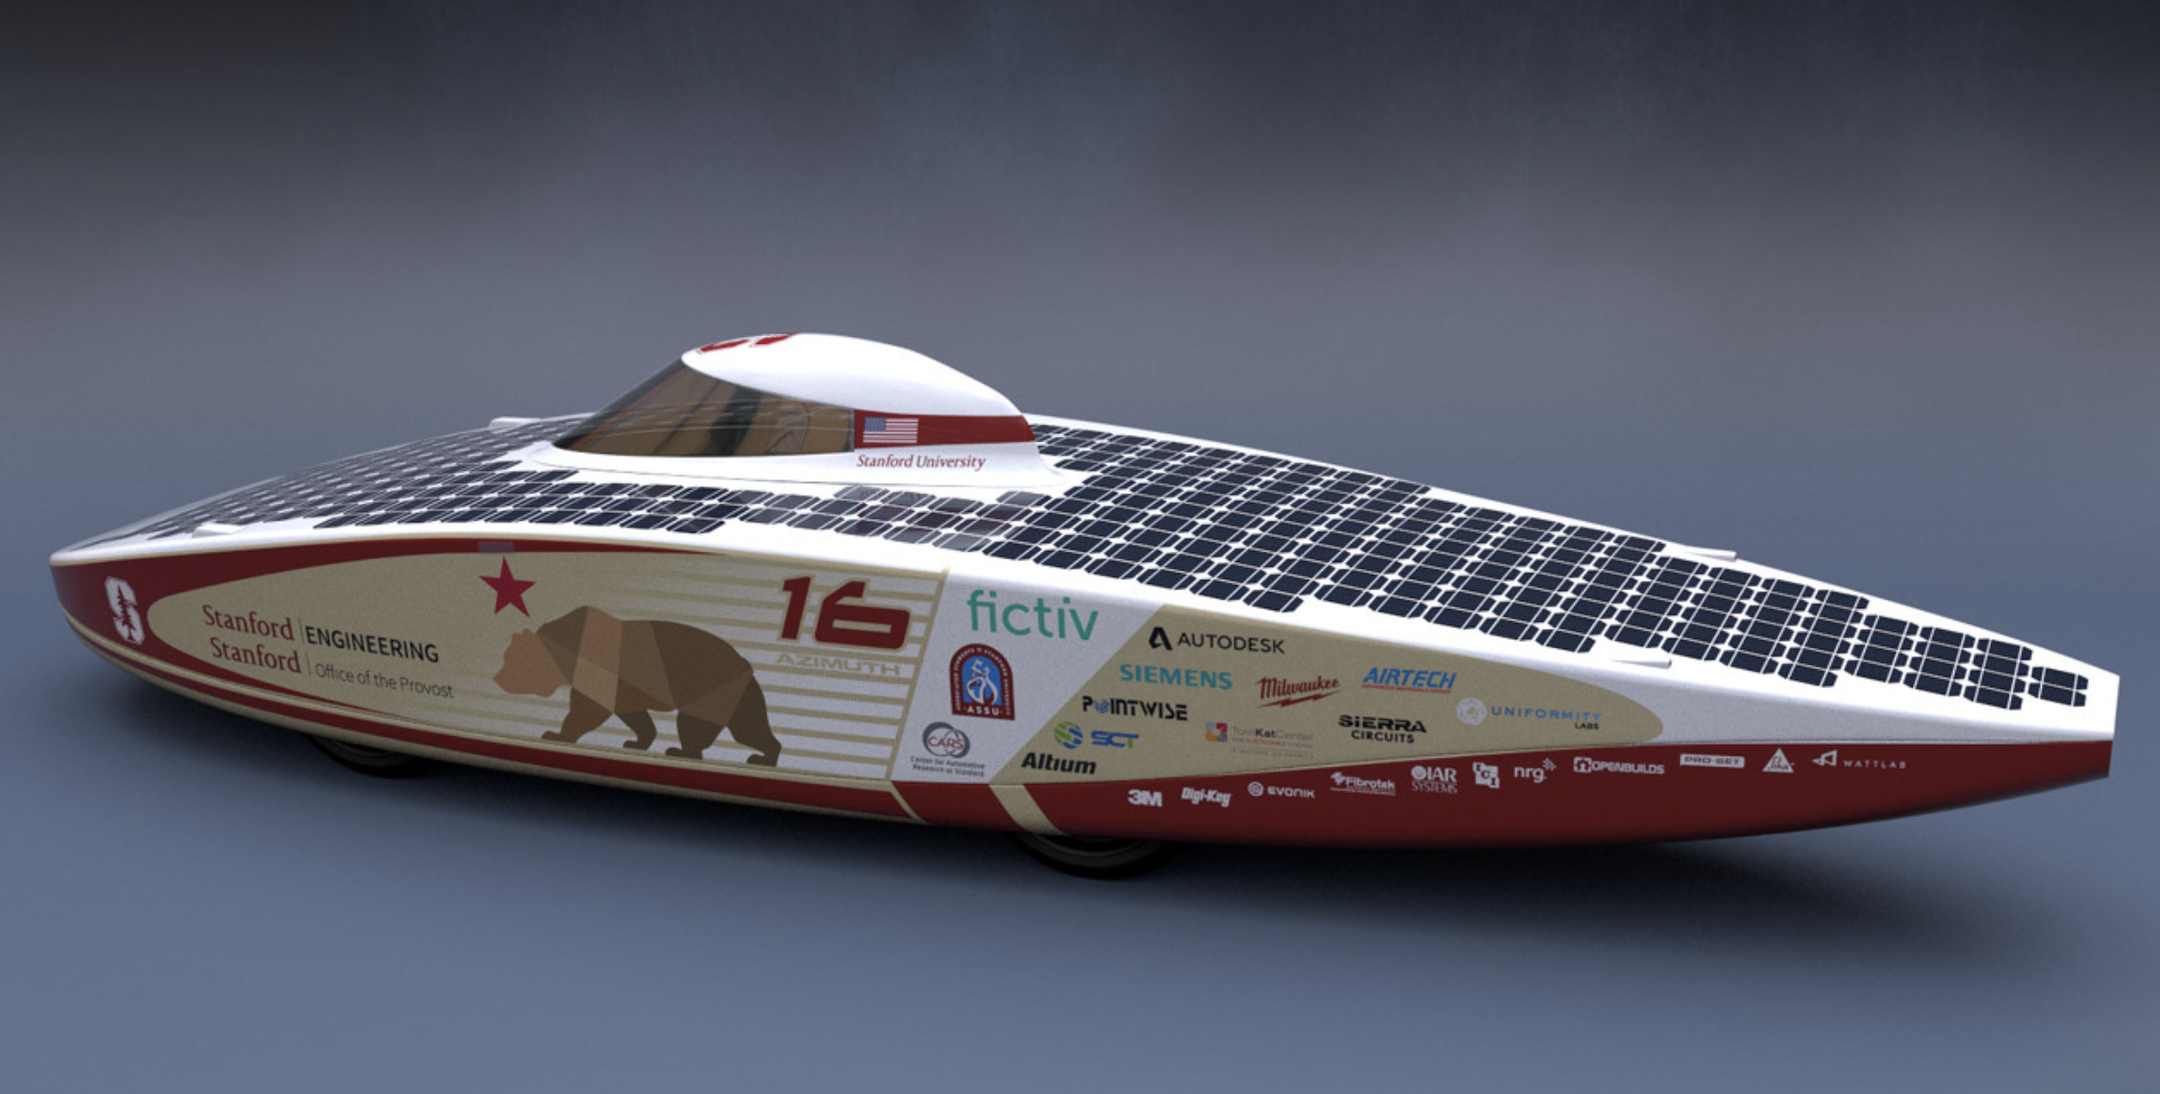
Goal & Constraints
Light, stiff, manufacturable structures and aerobody for Stanford's solar car. • Key constraint: mass vs stiffness, built by a student team • Target: safety factor 2–4 at peak suspension load
My Role
Structural & aero design — rear suspension hardpoint, roll cage, chassis integration, composite tooling, and aerobody geometry.
Design & CAD
Rear suspension control arm hardpoint, roll cage with mounting tabs, chassis, composite mold tooling, and aerobody / canopy geometry. • Control arm — triangulated geometry driven by load paths from the hardpoints • Roll cage — tube frame with mounting tabs, integrated into the chassis • Composite mold — tooling with a defined parting line for the aerobody layup • Aerobody — streamlined body and canopy geometry
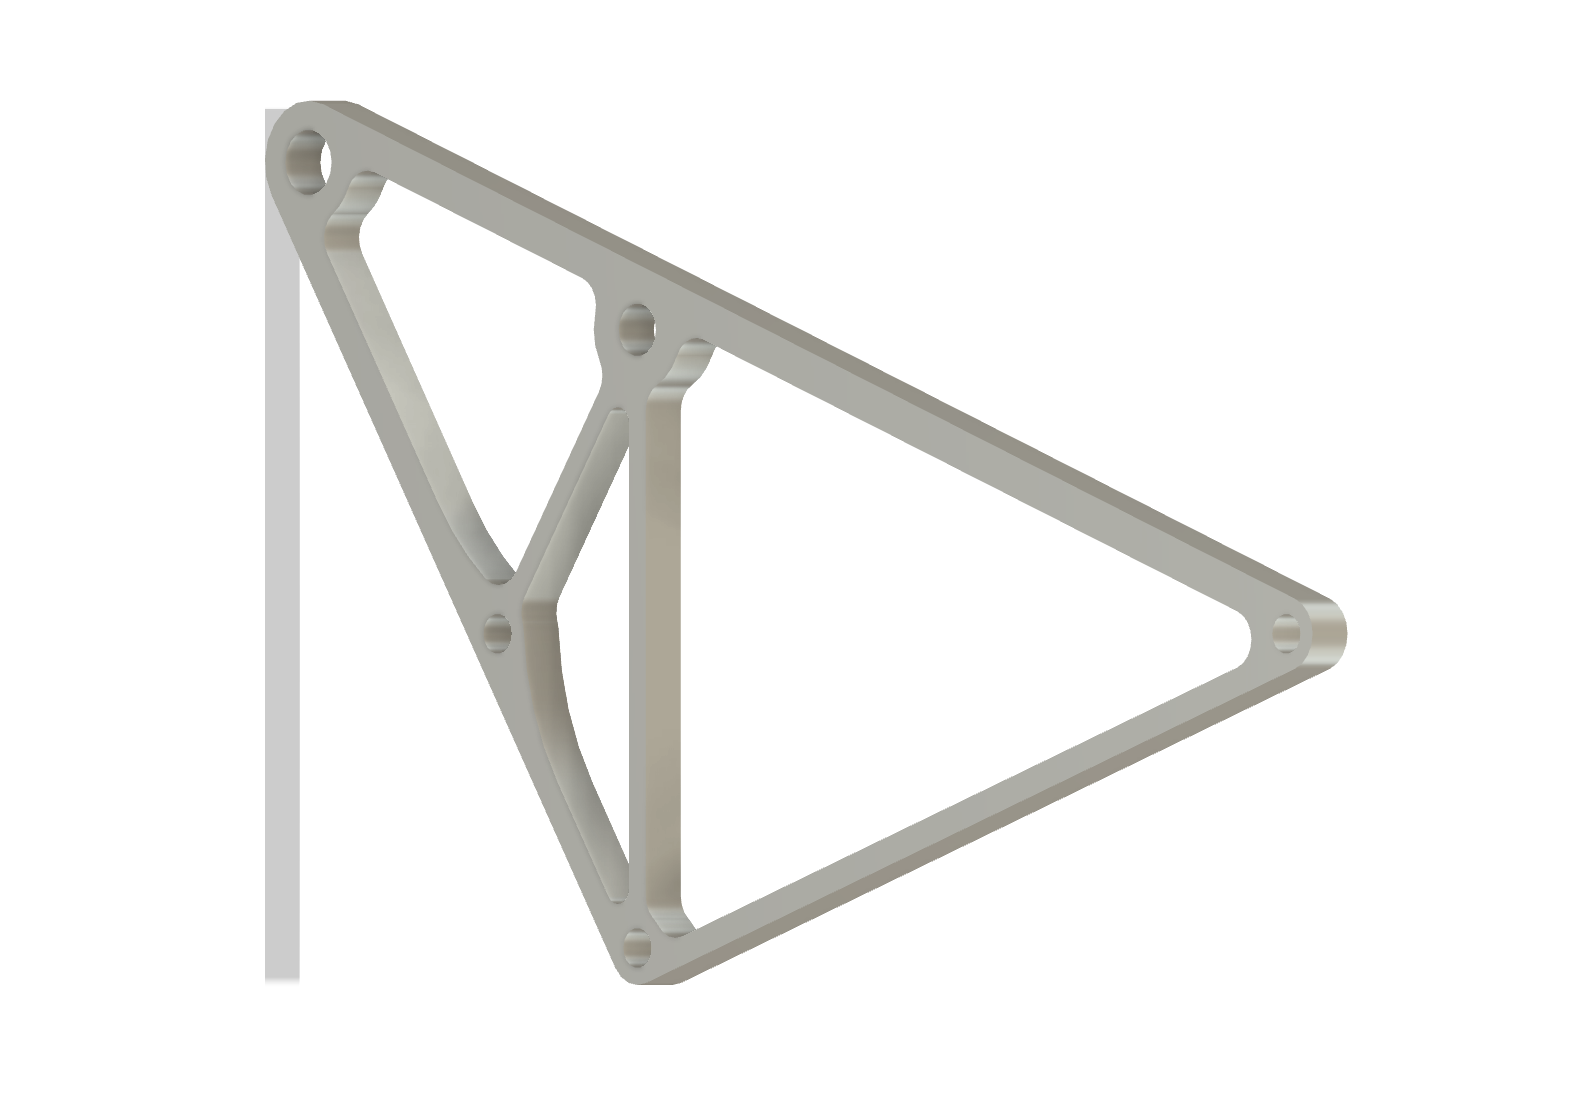
Control arm CAD — geometry driven by load paths
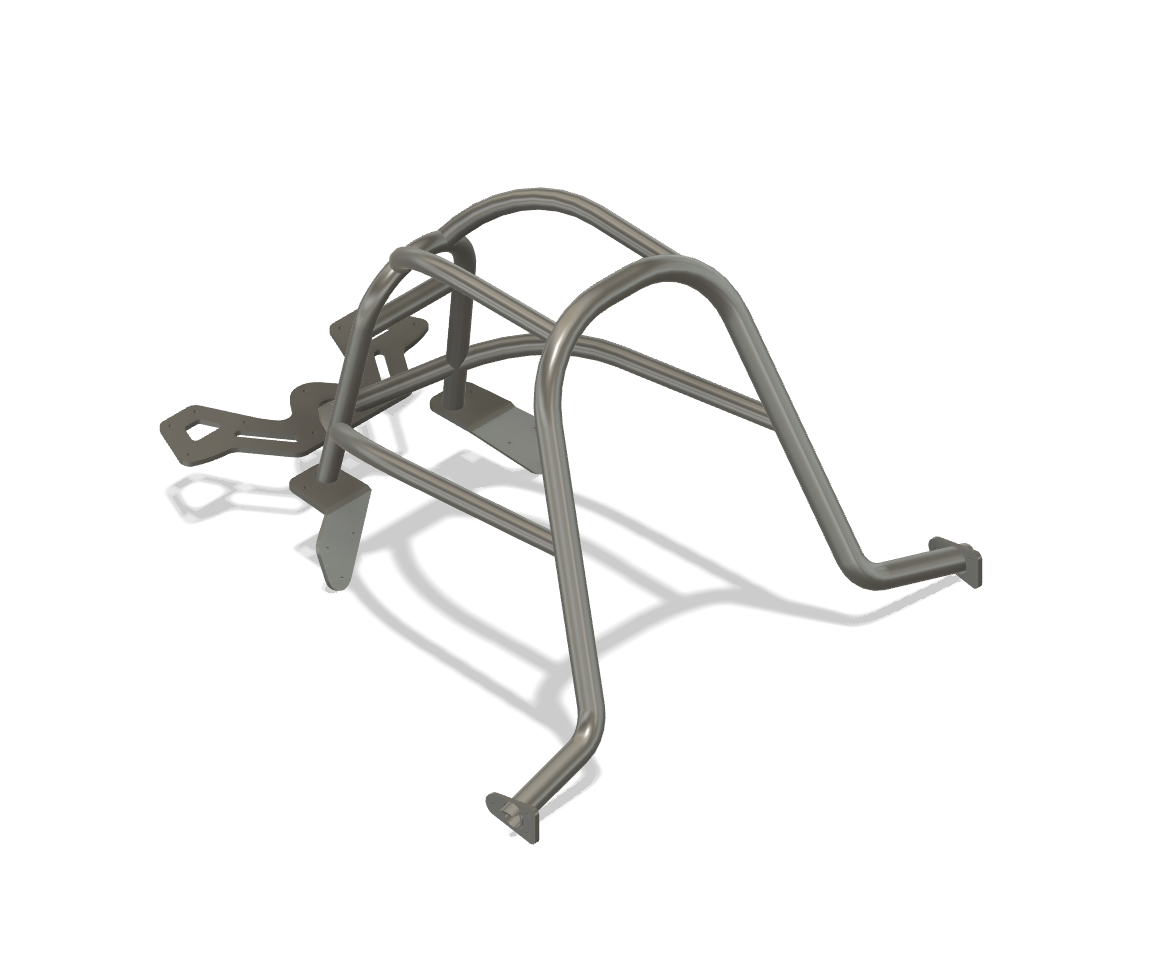
Roll cage with mounting tabs
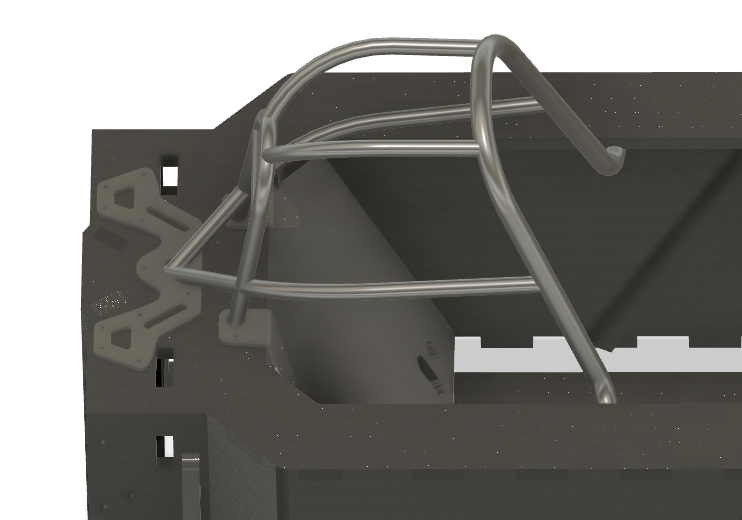
Roll cage integrated with chassis
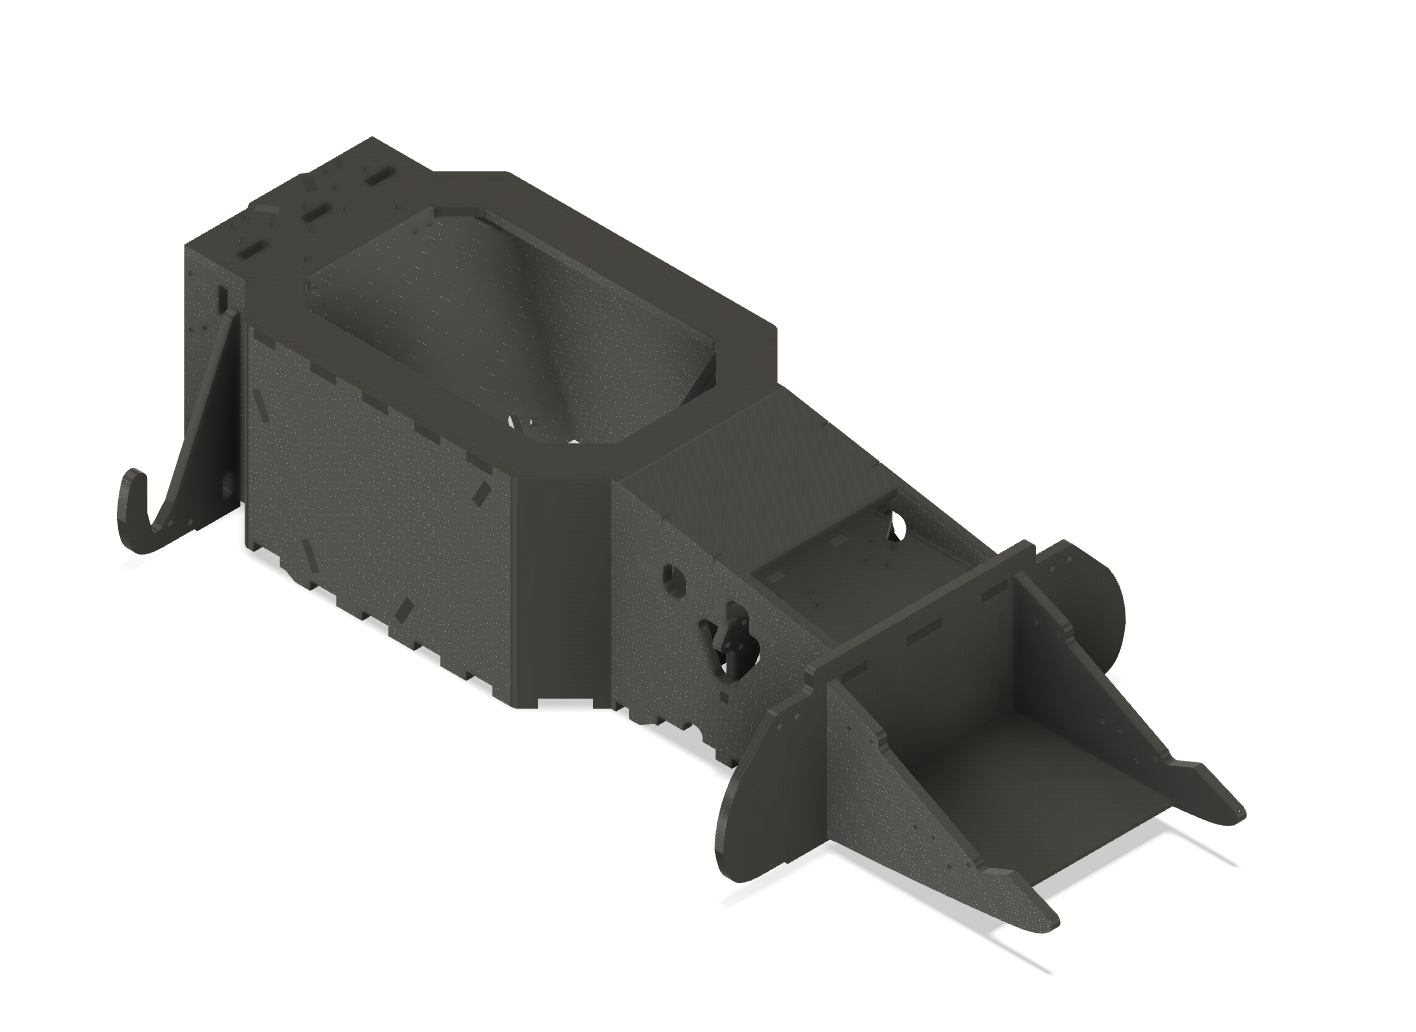
Chassis — isometric
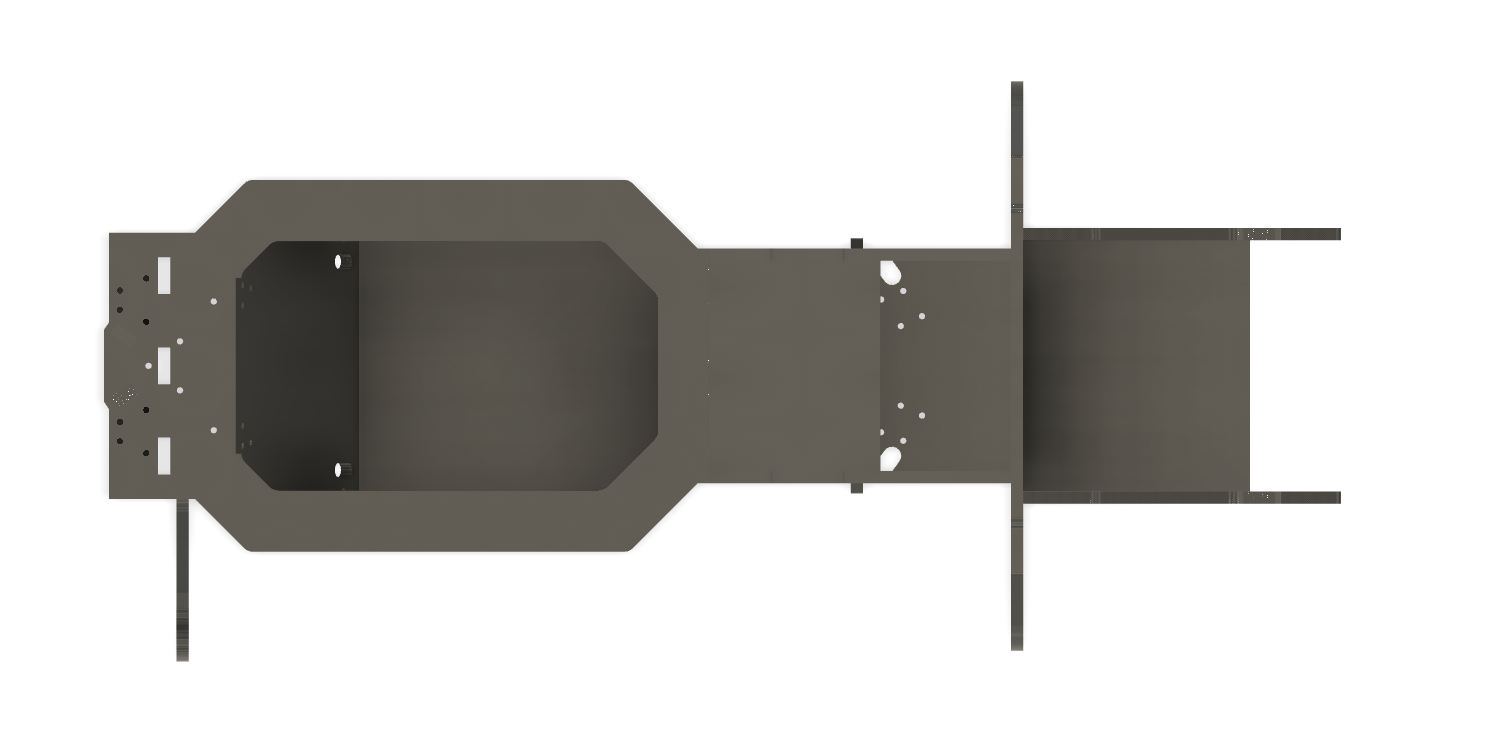
Chassis — top view
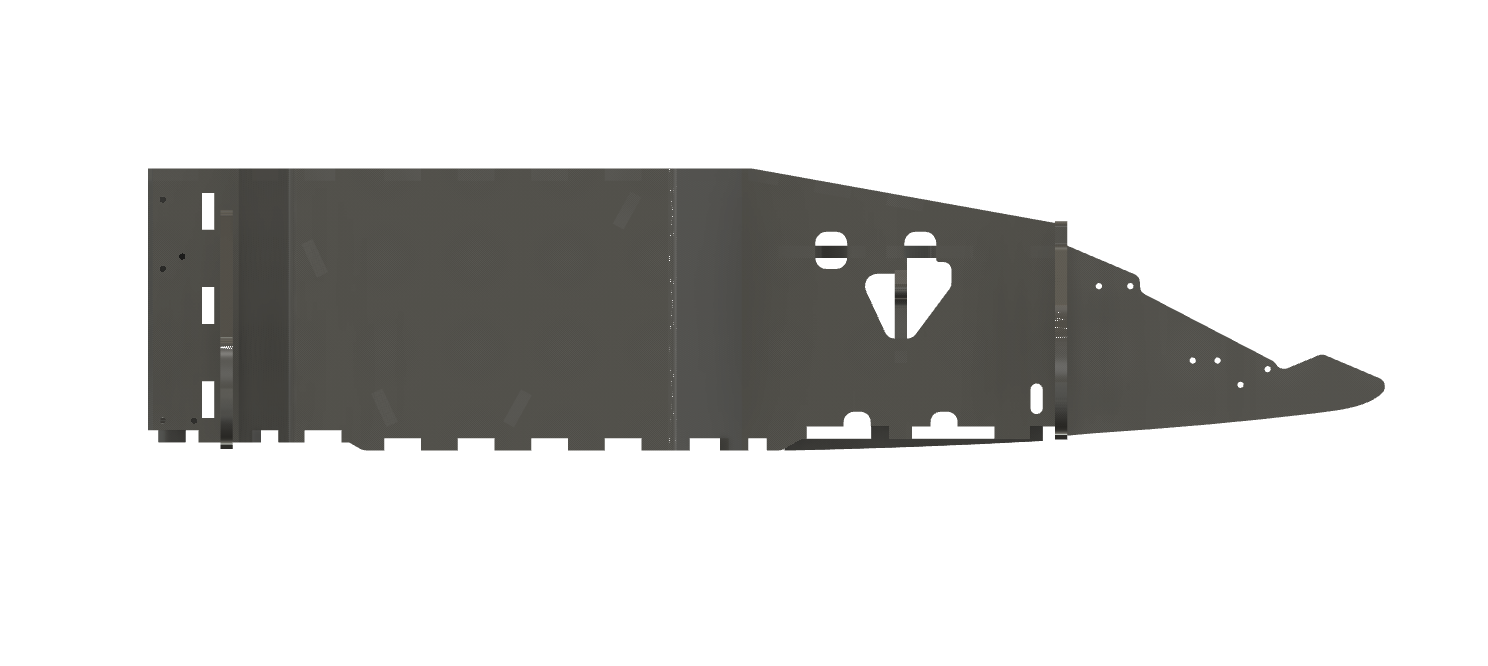
Chassis — side view
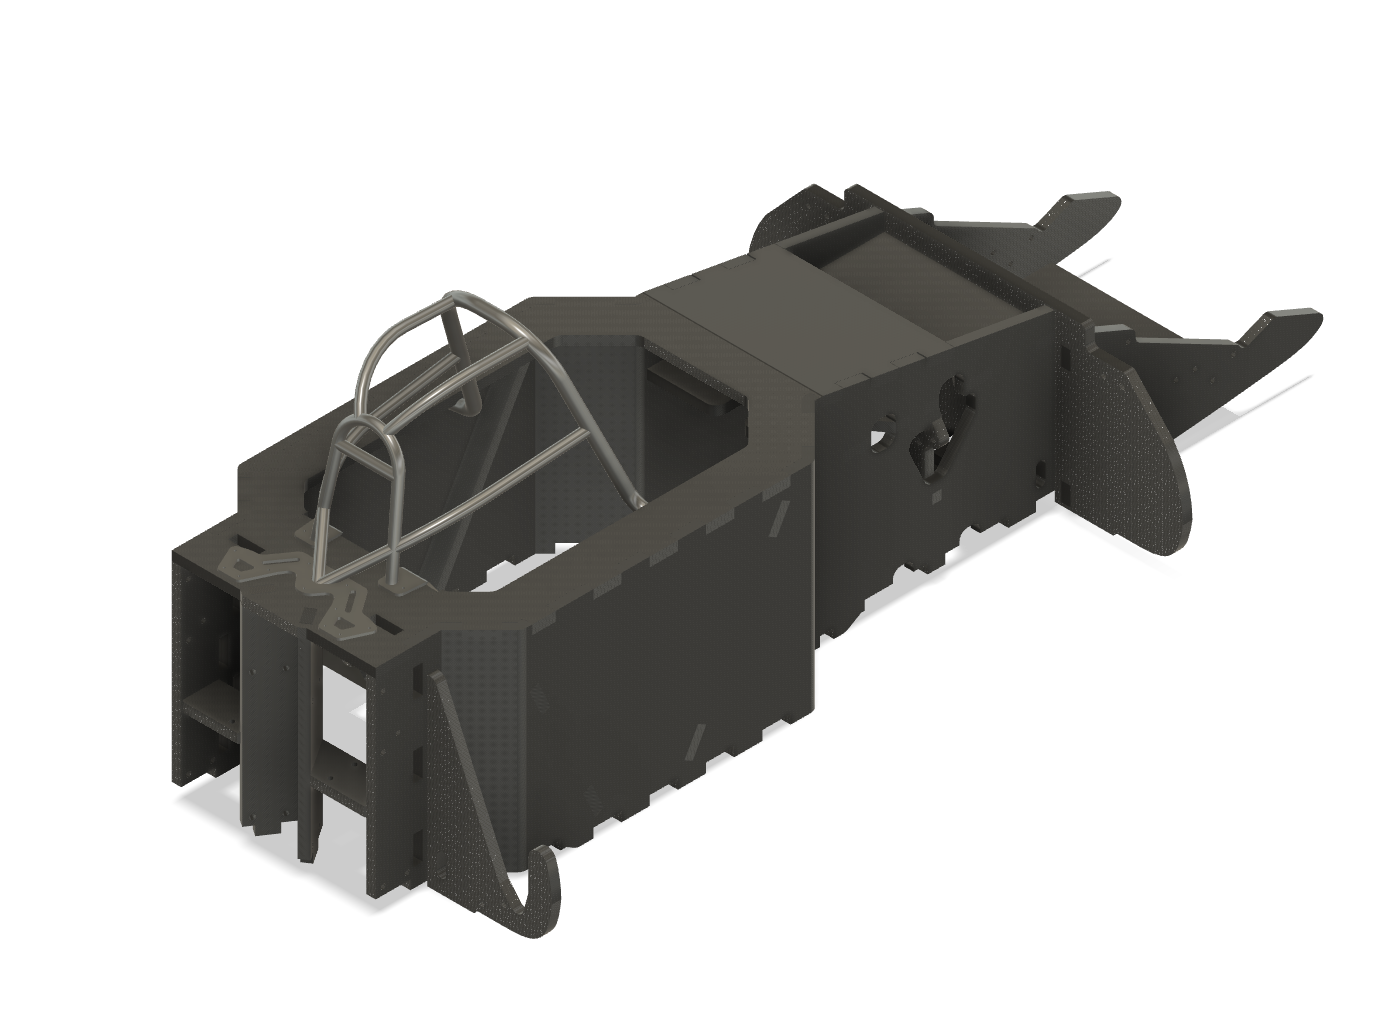
Chassis and roll cage integration
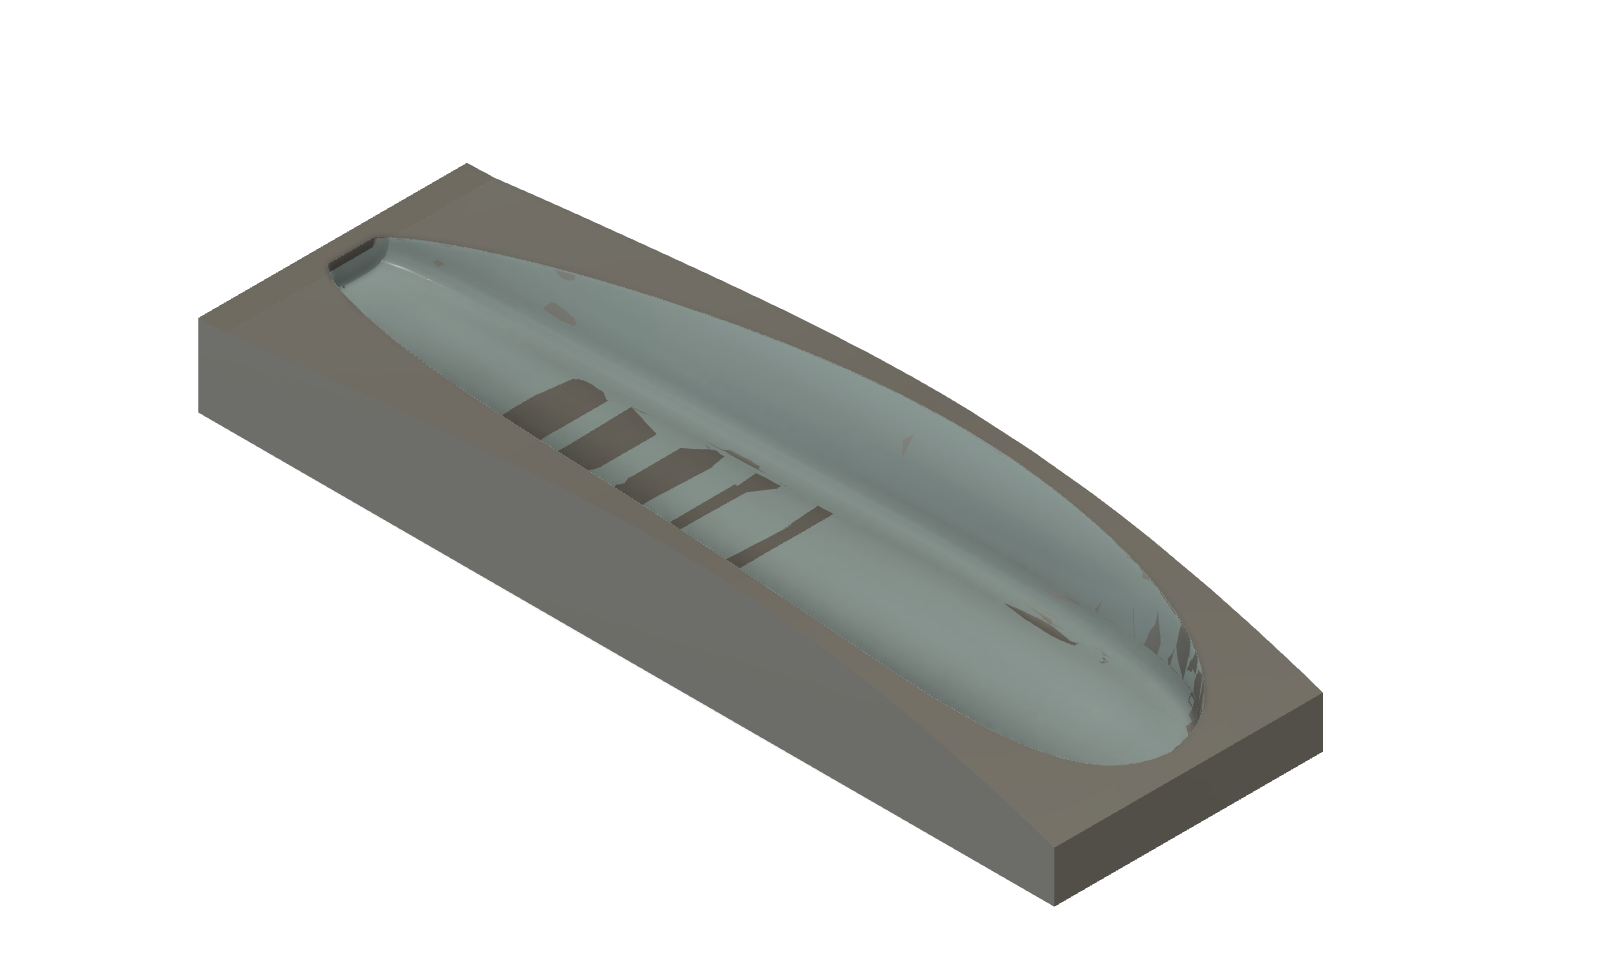
Composite mold — isometric
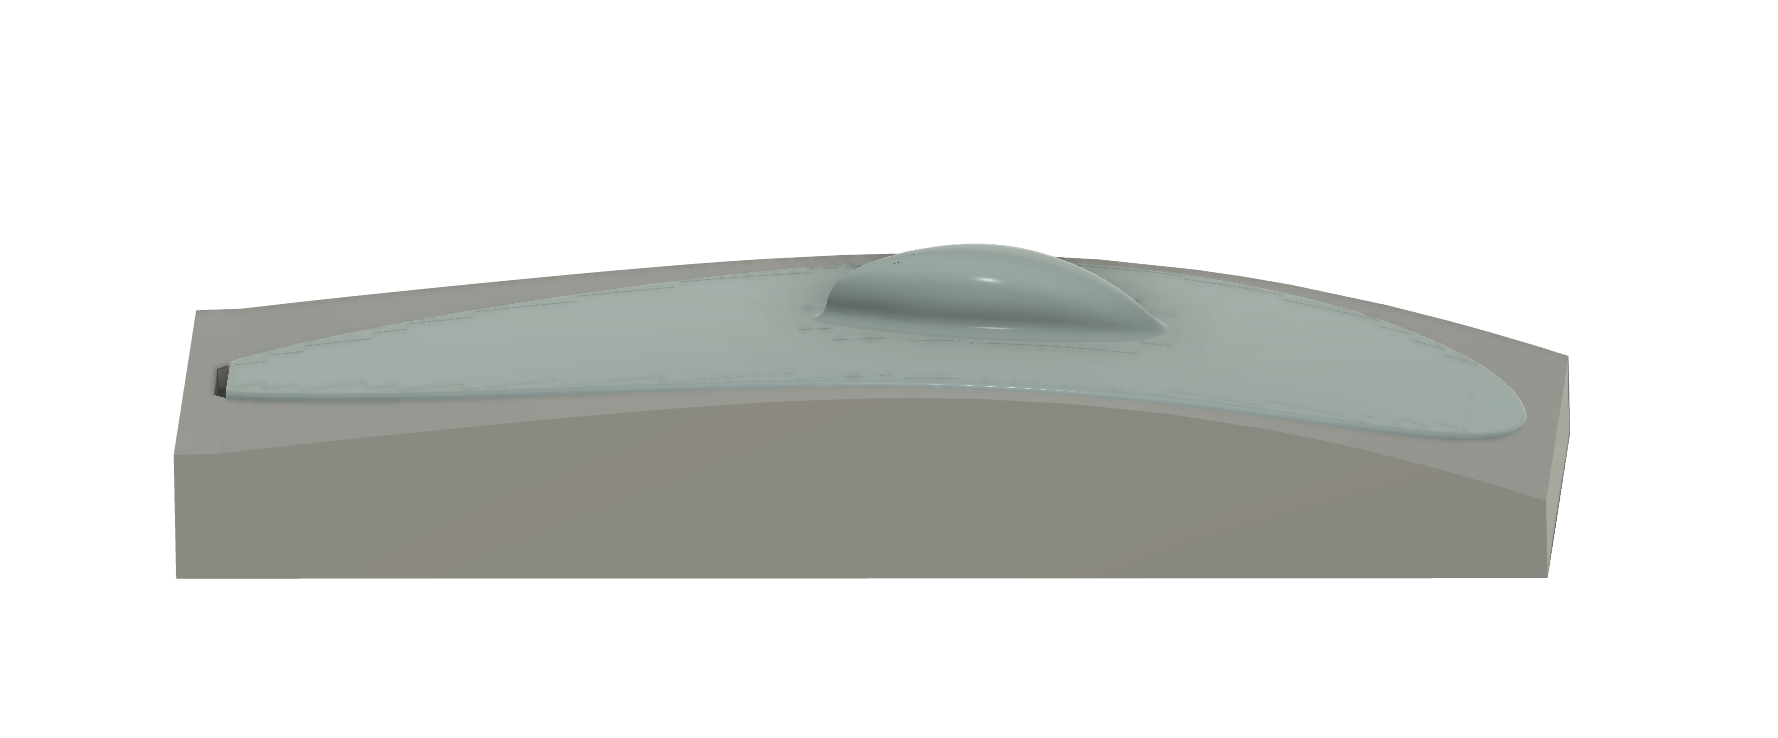
Composite mold — side profile, parting line
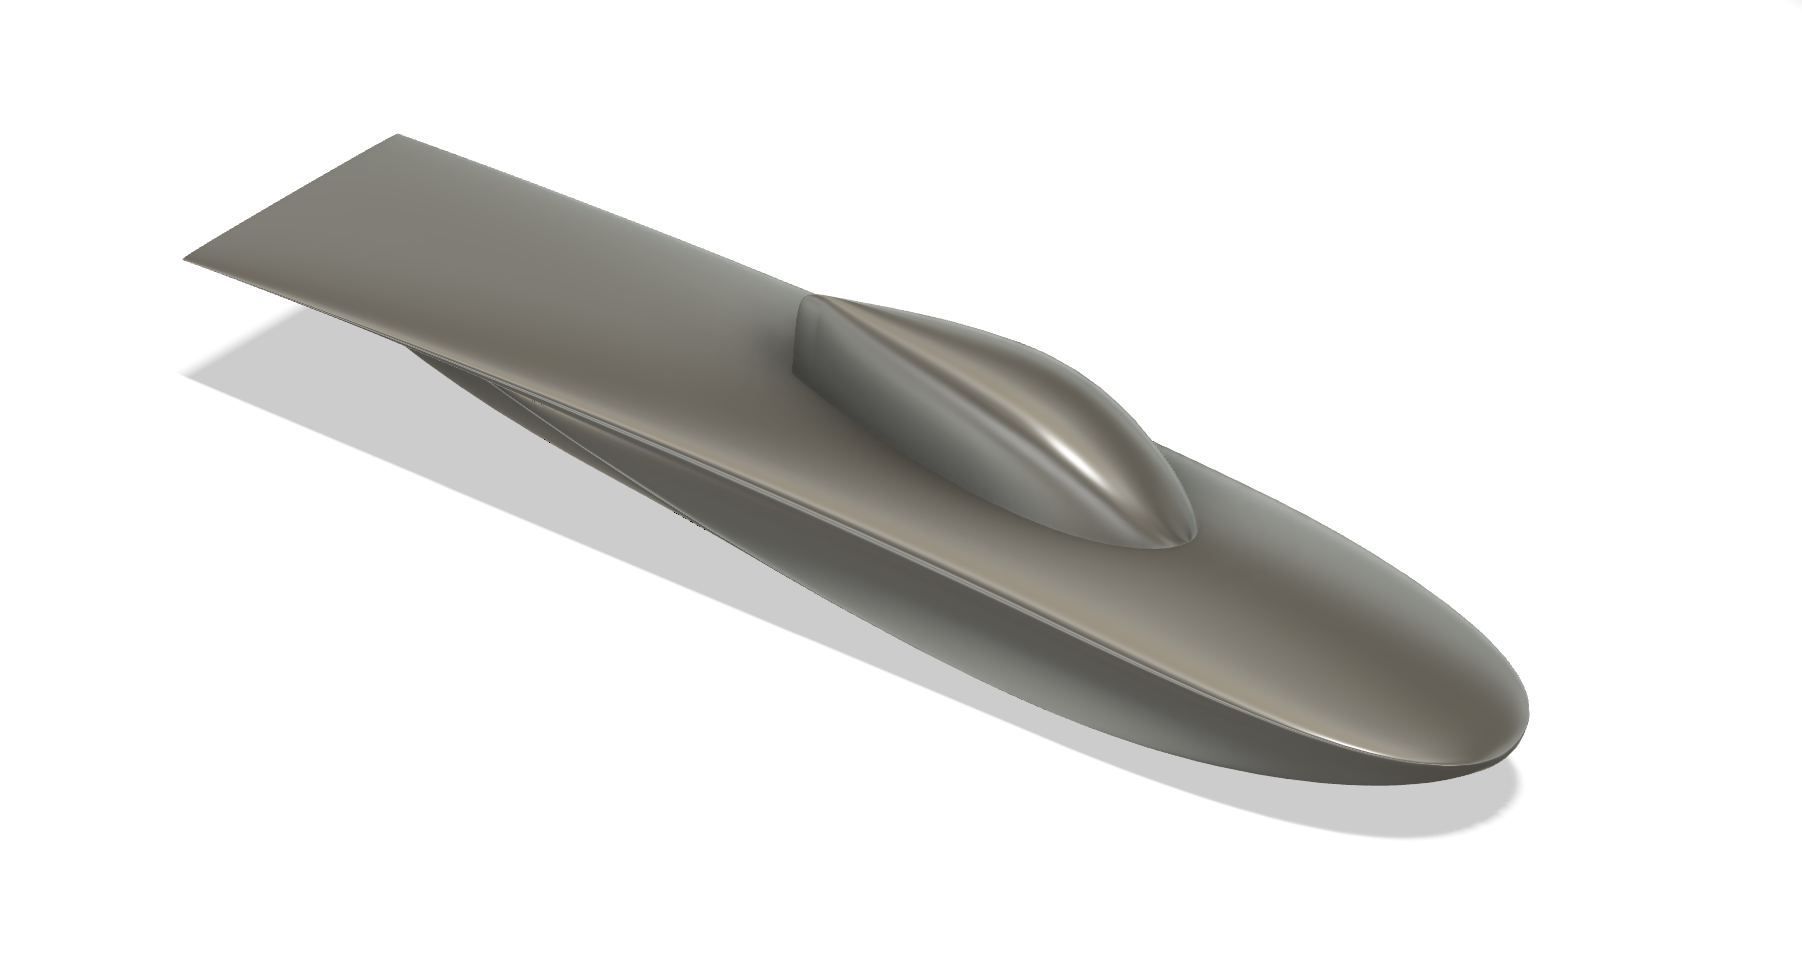
Aerobody with canopy
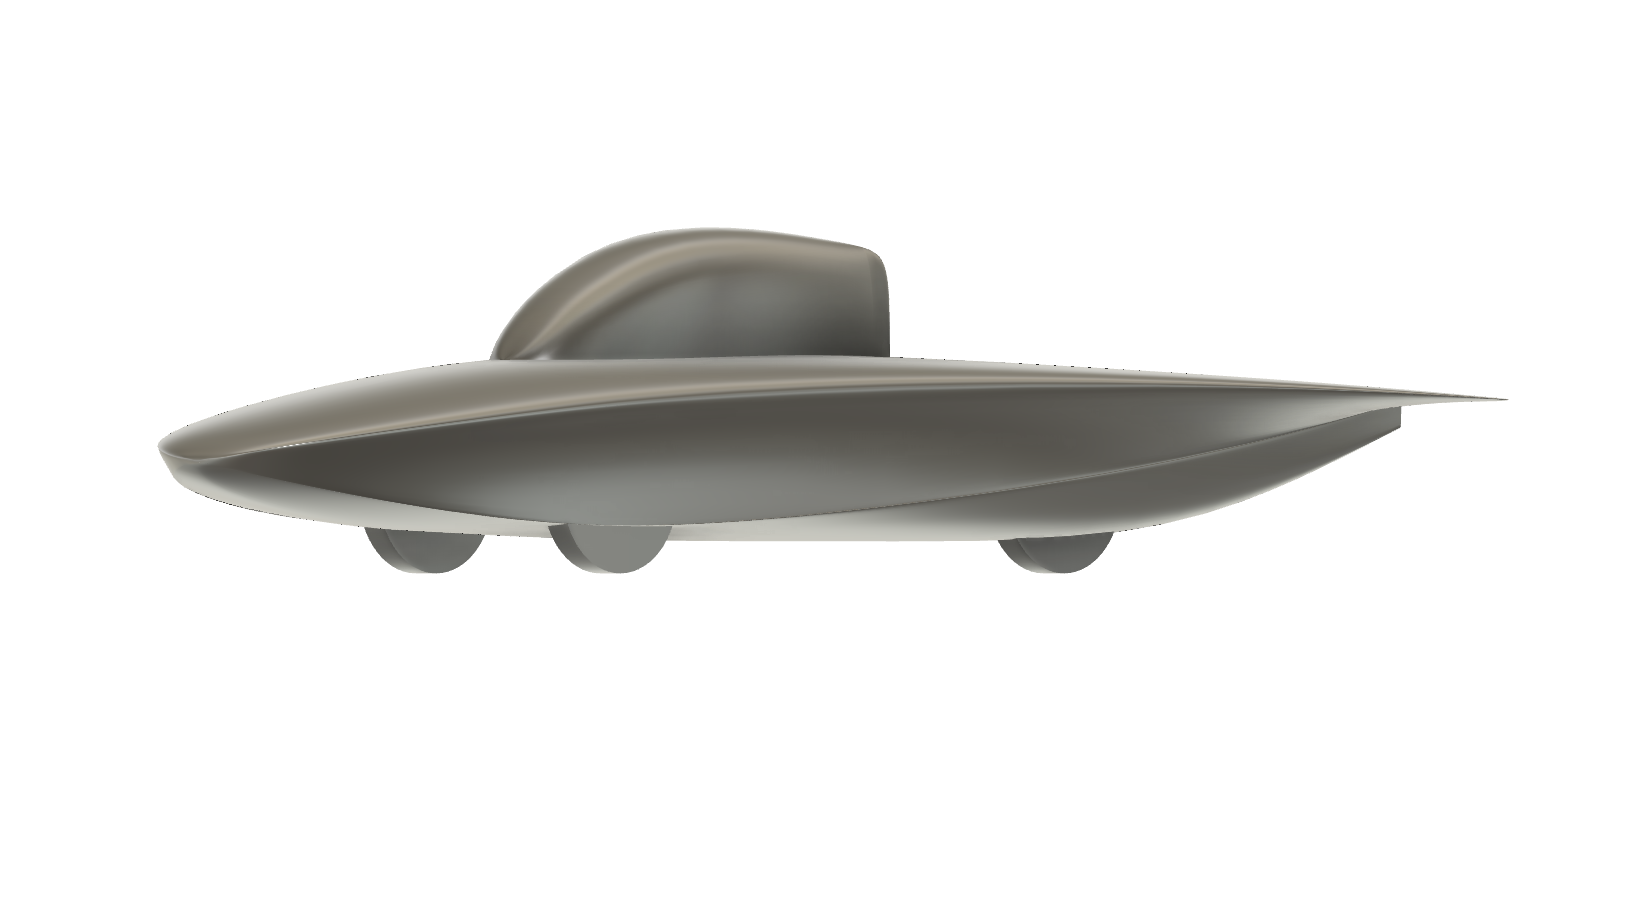
Aerobody — side profile
Test & Results
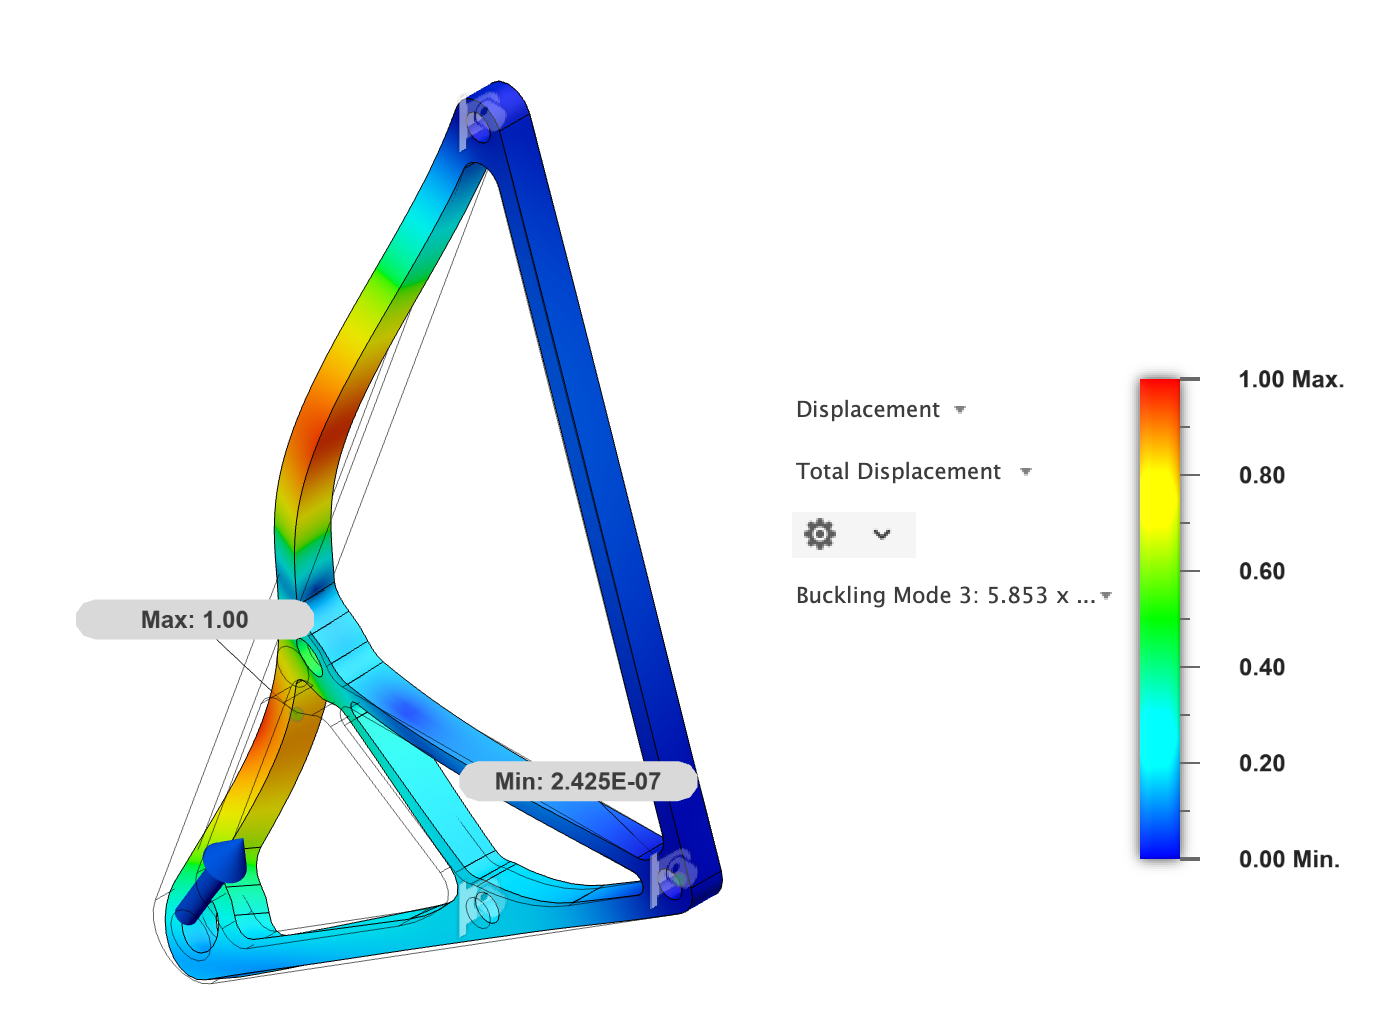
Buckling FEA — compressive suspension loads
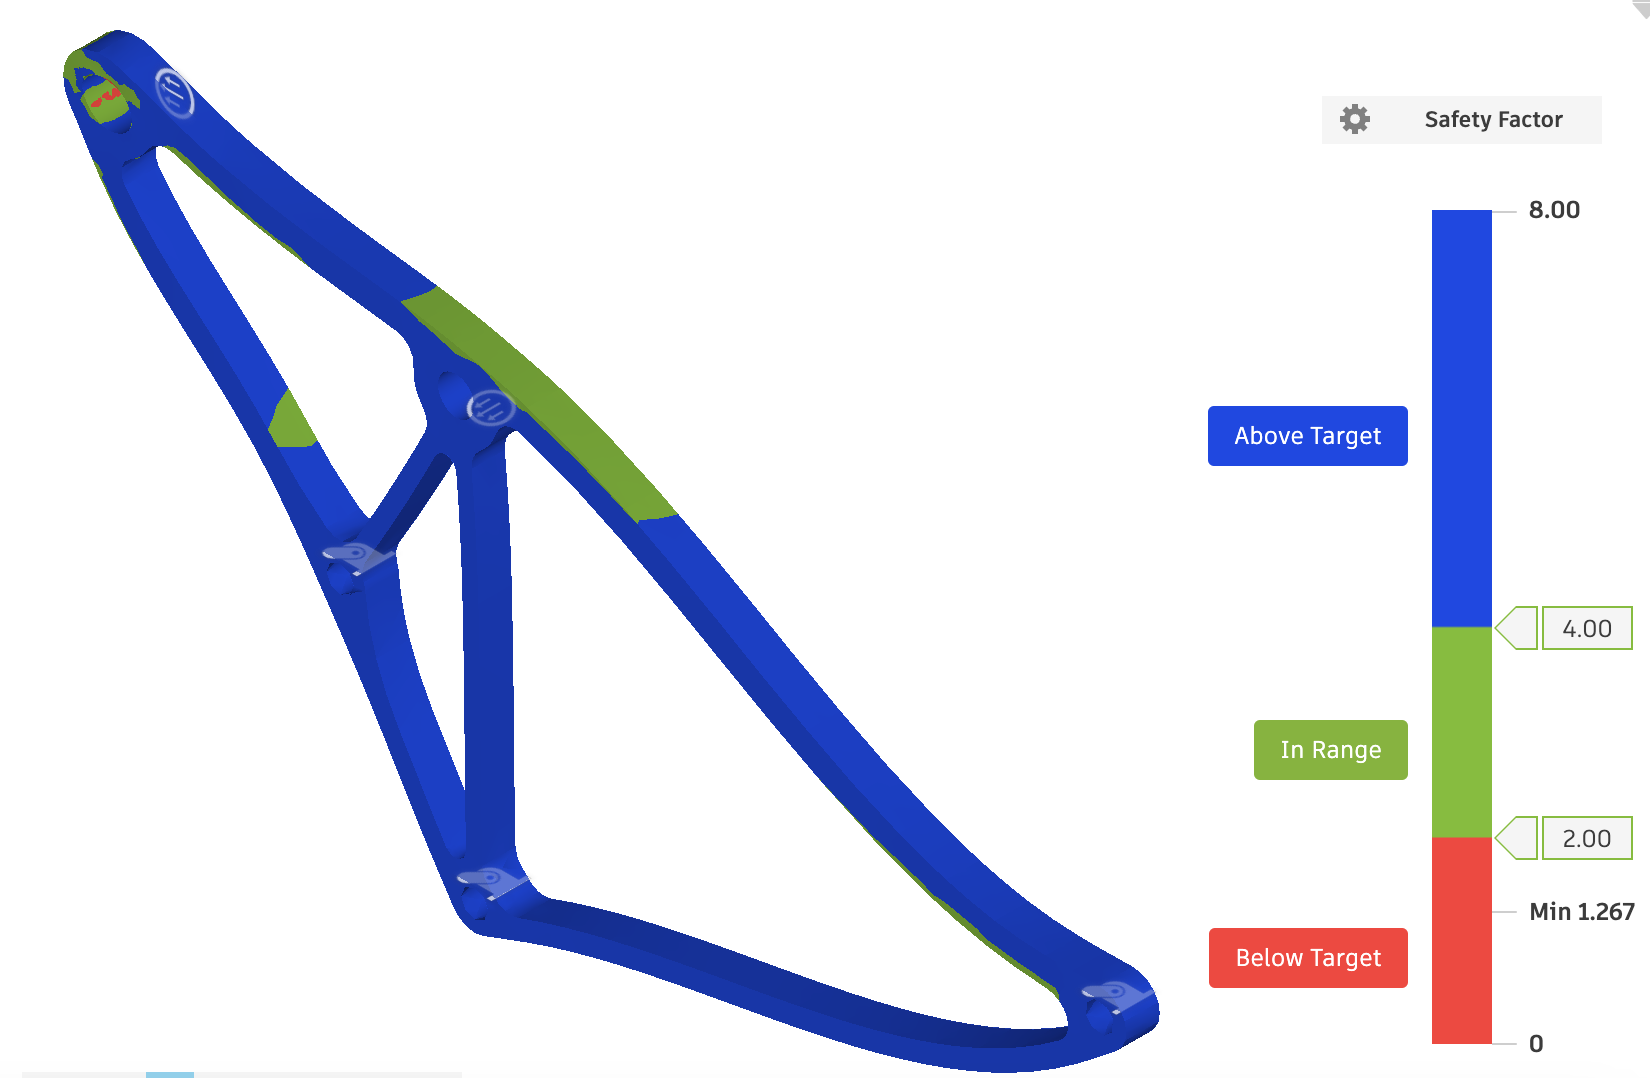
Static stress analysis — safety factor under peak load
• Static FEA: most of the arm above SF 4; peak-loaded members within target • Stiffer and stronger than the previous car's arm • Min SF 1.27 — localized peak, flagged for mesh refinement • Buckling FEA: strength-limited, not stability-limited

